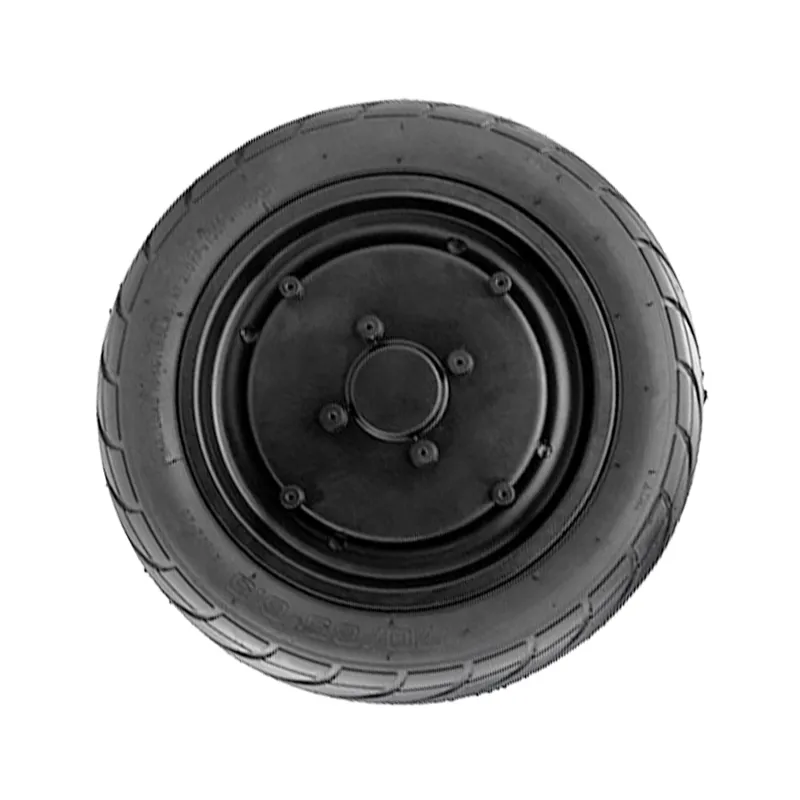
For electric equipment manufacturers, selecting a brushless hub motor is only one part of creating a workable drive system. Reliable operation also depends on whether the motor, controller, wiring interface, control logic, and installation conditions are considered together.
WINAMICS supports hub motor controller matching for electric mobility and specialized equipment applications. The objective is to help engineering and purchasing teams define compatible motor and controller requirements before prototype testing and production planning.
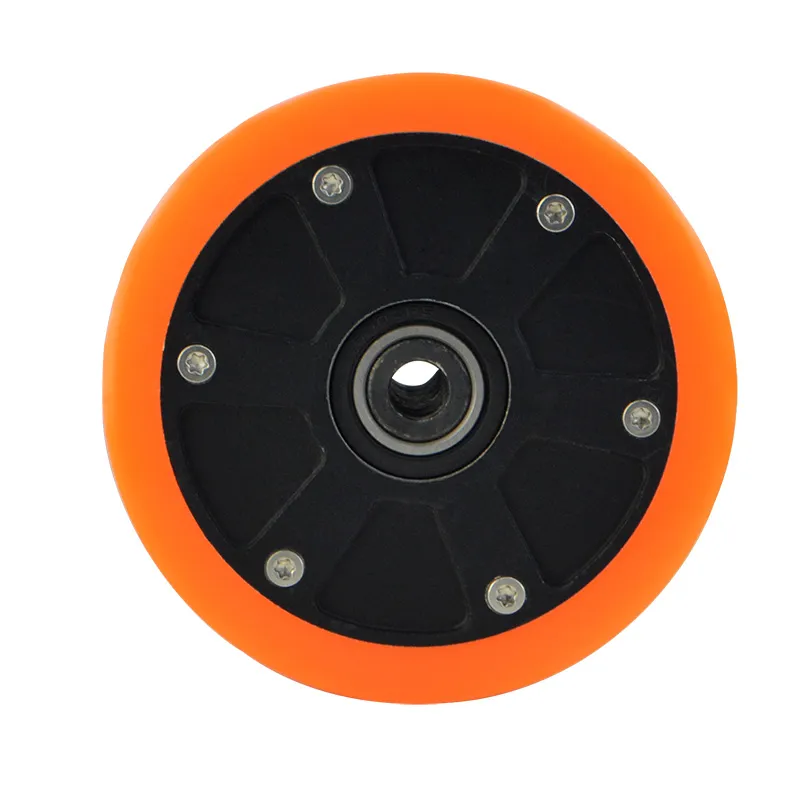
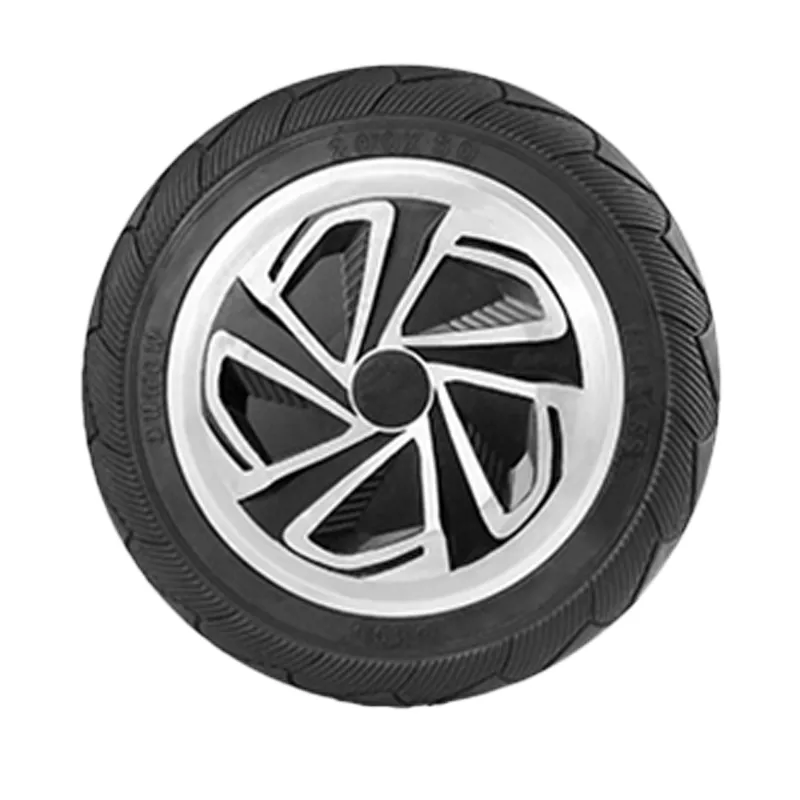
A brushless hub motor and its controller operate as a connected electric drive system. The motor provides the mechanical output at the wheel, while the controller manages power delivery and responds to operating commands such as acceleration, direction, and speed adjustment. If these elements are not aligned with the equipment’s actual load and operating conditions, integration may require additional revisions during development.
Controller matching is especially relevant for compact vehicles and mobile equipment that require direct drive, controlled low-speed movement, forward and reverse travel, or limited installation space. Typical applications include electric bumper cars, electric karts, carts and trolleys, AGVs, mobile robots, wheelchairs, lawn equipment, and other electrically driven platforms.
Motor voltage, target speed, torque demand, wheel size, vehicle load, duty cycle, and operating environment provide the starting point for controller selection and drive-system evaluation.
The required control method should be defined early, including speed control, forward and reverse operation, acceleration behavior, braking requirements, and the intended user or system interface.
Power connections, motor phase wires, signal wiring, connectors, cable routing, and interface definitions need to suit both the electrical design and the available equipment structure.
| Integration Item | Why It Should Be Defined |
|---|---|
| Voltage and power requirements | Helps align the motor and controller with the equipment’s electrical supply and expected operating conditions. |
| Speed and torque targets | Supports selection based on vehicle load, wheel diameter, required movement speed, starting demand, and terrain or surface conditions. |
| Forward and reverse operation | Clarifies directional control requirements for vehicles, robots, amusement equipment, and maneuvering applications. |
| Speed control method | Ensures the requested throttle, switch, control signal, or system command approach can be considered during matching. |
| Wiring interface and connectors | Reduces uncertainty around cable lengths, connector types, pin definitions, installation orientation, and service access. |
| Installation and operating environment | Allows the drive configuration to be reviewed in the context of available space, mounting structure, exposure conditions, and continuous-use expectations. |
Load changes, low-speed handling, starting torque, wheel selection, and practical cable routing are common points to address.
Drive direction, speed control response, compact integration, and communication with the equipment’s wider control design may require clear interface planning.
The motor and controller configuration should reflect the intended vehicle behavior, directional operation, duty cycle, installation space, and operating load.
Smooth low-speed control, compact wheel integration, forward/reverse operation, and the equipment’s structural dimensions are important design inputs.
As a manufacturer of brushless hub motors and customized electric drive solutions, WINAMICS works with equipment manufacturers, engineering teams, and OEM/ODM buyers on motor and controller solution requirements. Support can include:
For an effective hub motor controller matching discussion, prepare the vehicle or equipment load, target speed, wheel size, power supply voltage, required forward/reverse and speed-control functions, working environment, and available installation dimensions. This information gives WINAMICS a practical basis for evaluating a brushless hub motor and controller configuration for your electric drive integration project.
 hub motor brushless hub motor electric mobility motor robotics drive solution in-wheel motor
Shenzhen Jinhaixin Holdings custom brushless hub motor brushless hub motor parameters hub motor development process hub motor compatibility and operating conditions
Shenzhen Jinhaixin Holdings Co., Ltd low-voltage three-electric system brushless hub motor drive controller energy battery pack
Shenzhen Jinhaixin Holdings industrial motor selection motor size matching space-constrained motor solution motor power and space relationship
Jinhaixin Holdings low-voltage three-electric system matching motor controller battery compatibility B2B system selection electric powertrain stability