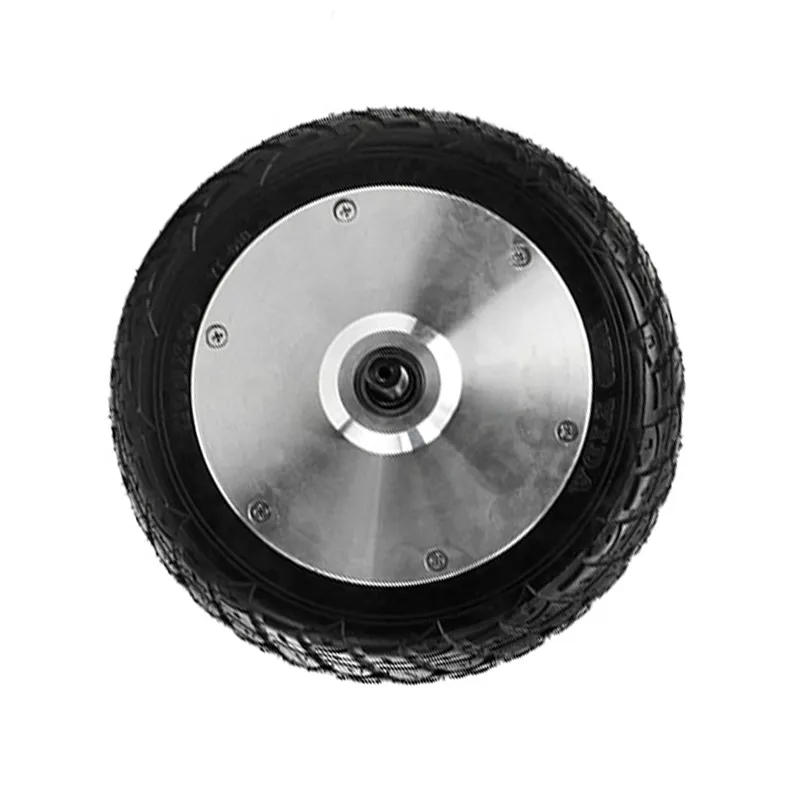
Selecting a brushless hub motor for a target vehicle speed starts with the wheel, not with the motor’s RPM rating alone. The wheel’s effective rolling circumference gives an initial estimate of the speed required at the wheel. Vehicle load, motor configuration, battery voltage, controller limits, and operating conditions then determine whether that estimate is practical for the application.
In brief: estimate wheel RPM from target speed and effective rolling circumference, then confirm how wheel speed relates to motor RPM for the specific hub motor. Treat the calculation as a starting point for selection and testing, not as a guaranteed vehicle speed.
For a target speed expressed in metres per second, use the wheel’s effective rolling circumference in metres:
Wheel RPM = (Vehicle speed in m/s ÷ Rolling circumference in m) × 60
If vehicle speed is given in kilometres per hour, convert it first: divide by 3.6 to obtain metres per second. The circumference can be estimated from the effective rolling diameter using Circumference = π × diameter. For a more representative estimate, use the tyre’s loaded rolling circumference where available; the nominal tyre diameter may not exactly reflect its size under load.
Illustrative calculation: For a target speed of 30 km/h (about 8.33 m/s) and an assumed effective rolling circumference of 1.26 m, the estimated wheel speed is about 397 RPM. This is a mathematical example only; it does not predict the speed of a particular vehicle or motor.
For a direct-drive hub motor, motor RPM is generally closely related to wheel RPM. A geared hub motor has an internal reduction ratio, so motor RPM and wheel RPM differ. Confirm the motor’s construction and the meaning of its published RPM specification before using the estimate for selection.
The calculated RPM is a kinematic estimate: it relates wheel rotation to distance travelled. It does not establish whether the motor and vehicle can reach or maintain the target speed. Check the following application factors:
| Common error | Why it matters | Better approach |
|---|---|---|
| Treating motor RPM as vehicle speed | The relationship depends on wheel circumference and, for geared motors, the reduction ratio. | Calculate wheel RPM and confirm the motor configuration. |
| Mixing units in the calculation | Using km/h as though it were m/s produces an incorrect estimate. | Convert speed and circumference to consistent units first. |
| Selecting from RPM alone | The figure does not account for load, voltage, controller limits, or operating conditions. | Evaluate the motor as part of the intended vehicle system. |
After estimating the required RPM, validate the proposed setup under conditions that reflect the intended application. Confirm the wheel measurement, motor configuration, battery voltage, controller settings, and vehicle load. During evaluation, compare measured vehicle speed and wheel or motor RPM with the expected relationship, and observe whether the system operates appropriately for the intended use.
Record the test conditions and results so that any difference between the estimate and observed performance can be reviewed. Testing should follow suitable equipment and vehicle safety procedures; a calculation alone cannot confirm system suitability.
WINAMICS can support brushless hub motor selection and testing evaluation based on application requirements. Sharing the target speed alongside wheel dimensions, vehicle load, voltage, controller information, and installation constraints helps create a more relevant basis for reviewing the required motor speed and system compatibility.
Not by itself. Vehicle speed also depends on wheel circumference and the motor’s relationship to the wheel. Load, voltage, controller limits, and operating conditions also matter.
Convert the speed to metres per second by dividing by 3.6, then divide by the wheel’s rolling circumference in metres and multiply by 60.
It can provide an initial estimate. The effective rolling circumference under load may differ, so use a measured or specified rolling circumference when available.
It is generally closely related for a direct-drive hub motor. For a geared hub motor, the internal reduction ratio changes the relationship; check the specific motor design.
Share the target speed, wheel dimensions, vehicle load, battery voltage, controller details, intended use, and installation constraints. Test information, if available, can also help inform the evaluation.
To discuss a brushless hub motor RPM requirement, contact WINAMICS with your application details. The target speed and wheel circumference provide a useful starting point; a suitable selection also considers the complete electrical and operating setup and should be evaluated against the intended application.
 Shenzhen Jinhaixin Holdings kart motor 213mm brake disc high-torque motor karting modification
Shenzhen Jinhaixin Holdings camper trailer motor selection 90 mm tire width fit 100 mm dropout hub motor camper trailer hub motor
WINAMICS electric material handling hub motor hub motor torque calculation hub motor speed selection brushless hub motor matching
Shenzhen Jinhaixin Holdings Co., Ltd lawn mower tire replacement lawn mower tire maintenance heavy-duty mower tire care slope operation tire selection
WINAMICS Hub Motor Controller Matching Brushless Hub Motor Integration Motor and Controller Solution Electric Drive Wiring Interface